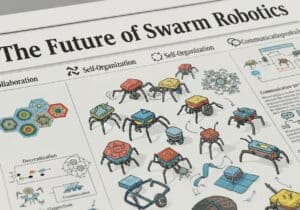
Swarm robotics investigates decentralized control mechanisms enabling large groups of robots to perform complex tasks collectively. Multi-robot coordination relies on distributed algorithms and consensus protocols to achieve formation control and collision avoidance. Stigmergy and bio-inspired algorithms guide self-organization and adaptive behavior within robotic swarms. Communication protocols facilitate robust information exchange, supporting task allocation and distributed sensing. Scalability and fault tolerance remain critical challenges in heterogeneous swarm systems.
This is our latest selection of worldwide publications and patents in english on Swarm Robotics, between many scientific online journals, classified and focused on swarm robotic, decentralized control, swarm intelligence, multi-robot coordination, distributed algorithm, robotic flocking, stigmergy, consensus algorithm, formation control, collision avoidance, robot localization, robot task allocation, robot communication protocol, robot self-organization, robot swarm scalability, bio-inspired algorithm, robotic exploration, distributed sensing, robotic aggregation, swarm robotics simulation, robotic path planning, robotic swarm navigation, robotic swarm deployment, robot adaptive behavior, robotic swarm learning, distributed decision making, robotic swarm mapping and heterogeneous swarm systems.
Avoiding trailer collisions based on localized mapping and field of view of obstacles
Patent published on the 2026-11-04 in EP under Ref EP4834686 by VOLVO TRUCK CORP [SE] (Johansson Daniel [se])
Abstract: [0001] Avoiding trailer collisions based on localized mapping and field of view of obstacles is disclosed herein. In one example, a computer system comprises processing circuitry that detects, during operation of a vehicle, an obstacle within a field of view of a sensor of the vehicle, and updates a local obstruction map with a location of the obstacle. When the vehicle is operated in a reverse direction, the processing circuitry determines location and position of a cab of the vehicle and locat[...]
Our summary: The system detects obstacles within a vehicle s sensor field of view and updates a local obstruction map. It determines the positions of the vehicle cab and trailer while reversing to assess potential collisions. Based on this assessment, it selects and executes a collision avoidance operation if necessary.
trailer collision avoidance, localized mapping, obstacle detection, field of view
Patent
Trailer collision avoidance system with trailer backtrack
Patent published on the 2026-10-22 in WO under Ref WO2026222348 by AUMOVIO AUTONOMOUS MOBILITY US LLC [US] (Burtch Joseph [us], Pathalil Nithin Joseph [us], Wartusch Benedikt [us], FÖrster Daniel [de])
Abstract: An integrated trailer collision‑avoidance system for a tow vehicle coupled to a trailer operates in a Trailer Turn Assist mode and a Trailer Backtrack mode. In Trailer Turn Assist mode, the system estimates a trailer path, detects objects in the estimated path, provides collision warnings during forward travel, determines whether a collision‑free forward path remains available, automatically stops the tow vehicle and enters a trailer reverse mode when no collision‑free forward path exists,[...]
Our summary: The system estimates trailer paths and provides collision warnings. It automatically stops the tow vehicle when no forward path is available. In reverse mode, it records axle positions to assist in escaping stuck conditions.
trailer collision avoidance, trailer turn assist, autonomous reverse maneuvering, object detection
Patent
Microservice-based solution for robot motion planning
Patent published on the 2026-10-22 in US under Ref US20260326295 by SONY GROUP CORP [JP] (Johnson David M S [us], Tayoun Anthony [us], Sadraddini Sadra [us], Stevens Brook [us], Bambrick David [us], Yammine Ramy [us])
Abstract: [0000] A microservice solves task and motion plans using a graph-of-convex-sets approach. The goal is to achieve time-optimal robot trajectories that are guaranteed to satisfy constraints, such as collision avoidance, end-effector pose and recipe-specific dynamic limits. The planning service includes a plurality of microservices, including one or more of a motion planner, an artifact builder, a visualizer, a planner, a service API and a service client. The planning service can use a combination [...]
Our summary: This solution utilizes microservices to generate time-optimal robot trajectories. It employs a graph-of-convex-sets approach to ensure constraints are met. The architecture includes various components such as motion planners and visualizers for enhanced functionality.
Microservices, Motion Planning, Robot Trajectories, Optimization
Patent
Post-avoidance maneuver control system and method
Patent published on the 2026-10-07 in EP under Ref EP4819104 by THE BOEING CO [US] (Rupnik Brian Kenyon [us], Torres Gamiz Alejandro [es], Gibson James Michael [us], Hicks Luke Casey [us], Pardo-gomez Emilia [es], Gersh Dannah Ruth [us], Reitsma Jelmer Pascal [de])
Abstract: An aircraft includes a memory configured to store flight mode data and one or more processors coupled to the memory. The one or more processors are configured to receive an indication of conclusion of a Resolution Advisory (RA) of a Traffic alert and Collision Avoidance System (TCAS) event. In response to receiving the indication of conclusion of the RA, the one or more processors are configured to automatically initiate a Post-Avoidance Maneuver (PAM). The PAM includes retrieval of at least a p[...]
Our summary: The system automatically initiates a Post-Avoidance Maneuver after a Resolution Advisory concludes. It retrieves flight mode data from before the advisory event. Control settings of the aircraft are adjusted based on the identified pre-RA flight mode.
Post-Avoidance Maneuver, Traffic Alert and Collision Avoidance System, Flight Mode Data, Aircraft Control
Patent
Method, computer program, computer-readable data carrier, control module, collision avoidance system and aircraft configured for providing collsision
Patent published on the 2026-09-30 in EP under Ref EP4814923 by AIRBUS OPERATIONS GMBH [DE] (Werthmann Christopher Victor [de], Bachmann Thomas [de], Friedel Andreas [de])
Abstract: [0001] A method of configuring a collision avoidance system for a vehicle, such as an aircraft, for warning an operating person (P) of the vehicle, such as a pilot, of a collision potential (U) with an object (O), such as another aircraft, a corresponding computer program, computer-readable data carrier, control module, collision avoidance system, and vehicle, in particular an aircraft, provided, wherein the method comprises the steps of detecting the object (O) with the collision avoidance syst[...]
Our summary: This method configures a collision avoidance system for aircraft. It detects potential collisions and assesses their risk. A warning signal is issued to the pilot if the risk exceeds a set threshold.
collision avoidance, aircraft, warning signal, control module
Patent
Method, computer program, computer-readable data carrier, control module, collision avoidance system and aircraft configured for providing distance va
Patent published on the 2026-09-30 in EP under Ref EP4814924 by AIRBUS OPERATIONS GMBH [DE] (Werthmann Christopher Victor [de], Friedel Andreas [de], Bachmann Thomas [de])
Abstract: [0001] A method of configuring a collision avoidance system for a vehicle, such as an aircraft, for warning an operating person (P) of the vehicle, such as a pilot, of a collision potential (U) with an object (O), such as another aircraft, a corresponding computer program, computer-readable data carrier, control module, collision avoidance system, and vehicle, in particular an aircraft, provided, wherein the method comprises the steps of detecting the object (O) with the collision avoidance syst[...]
Our summary: The method configures a collision avoidance system for aircraft. It detects objects and determines distance values. A warning is issued to the pilot if collision potential exceeds a threshold.
collision avoidance, aircraft, distance measurement, control module
Patent
Computational framework for makespan-aware multi-robot task allocation in obstacle-rich environments
Published on 2026-07-25 by @OXFORD
Abstract: AbstractStatic multi-robot task allocation in obstacle-rich environments becomes more challenging as the problem size increases because trivial and contested assignments are typically addressed during the same planning process. This paper presents the computational depot-frontier growth partitioning (DFGP) framework for organizing assignment decisions in static depot-aware multi-robot task allocation. In a centralized, full-information setting, DFGP expands depot-centred frontiers so that tasks [...]
Our summary: The DFGP framework organizes task assignments in multi-robot systems within obstacle-rich environments. It utilizes depot-centered frontiers to manage tasks efficiently, resolving contested assignments through entropy-based prioritization. Benchmark evaluations demonstrate DFGP s effectiveness, achieving a lower-bound gap of 8.5% and efficient runtime performance.
multi-robot task allocation, obstacle-rich environments, computational framework, depot-frontier growth partitioning
Publication
Rural e-commerce logistics path optimization method by carbon emission costs and CCSO
Published on 2026-06-25 by @OXFORD
Abstract: AbstractThis study tackles nonlinear programming challenges caused by the dual constraints of sparse, discrete rural e-commerce logistics networks and low-carbon time requirements. The study develops a path optimization model that combines a carbon tax mechanism with dynamic scheduling strategies. Traditional swarm intelligence algorithms often fall into local optima and lose population diversity in high-dimensional discrete spaces. To address these issues, this study proposes an improved Chicke[...]
Our summary: This study presents a path optimization model for rural e-commerce logistics that incorporates carbon emission costs. It introduces an improved Chicken Swarm Optimization (CCSO) to enhance global search capabilities. The results indicate significant reductions in operational and carbon emission costs through optimized routing.
path optimization, carbon emissions, Chicken Swarm Optimization, rural logistics
Publication