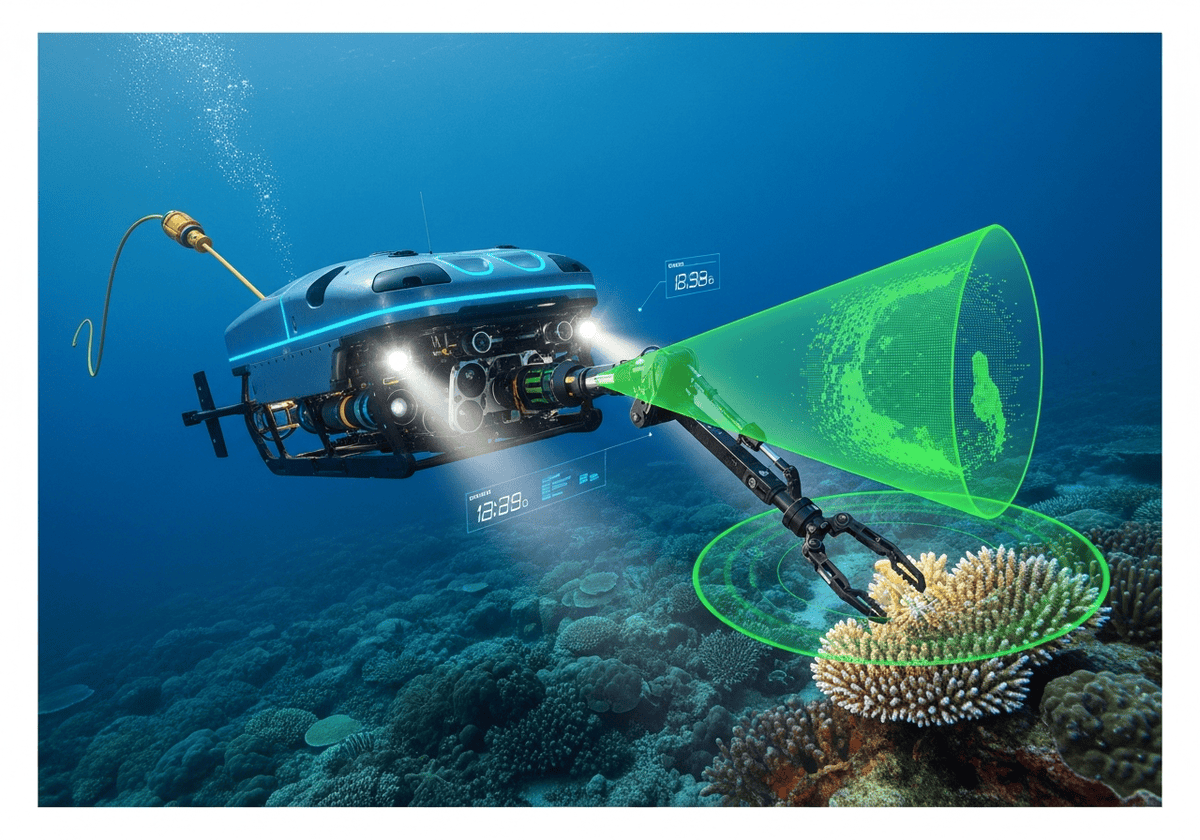
I veicoli sottomarini a comando remoto (ROUV) e i veicoli a comando remoto (ROV) integrano il controllo avanzato dei propulsori, la gestione dei cavi, la navigazione subacquea e la fusione dei sensori per eseguire operazioni precise in ambienti sottomarini. I componenti critici includono alloggiamenti resistenti alla pressione, sistemi di manipolazione, imaging sonar e telemetria in tempo reale che consentono l'ispezione, la manutenzione e l'acquisizione dei dati a profondità variabili e terreni complessi. I progressi della ricerca si concentrano su algoritmi di autonomia, ottimizzazione idrodinamica, gestione dell'energia e comunicazione protocols to enhance operational endurance and maneuverability. This collection compiles the latest peer-reviewed publications and patents detailing innovations in vehicle design, control architectures, mission planning, and payload integration driving subsea robotic capabilities.
Questa è la nostra ultima selezione di pubblicazioni e brevetti mondiali in inglese su veicoli subacquei a comando remoto (ROUV) e veicoli a comando remoto (ROV), tra molte riviste scientifiche online, classificate e focalizzate su controllo del propulsore, navigazione subacquea, gestione del tether, sistema sonar, manipolatore ROV, comunicazione subacquea, autonomia ROV, alloggiamento a pressione, carico utile ROV, idrodinamica, pianificazione della missione ROV, imaging subacqueo, veicolo subacqueo, sistema di controllo ROV, gestione dell'energia ROV, profondità nominale ROV, galleggiamento ROV, propulsore ROV, sonar ROV, streaming video ROV, veicolo subacqueo a comando remoto, veicolo a comando remoto, posizionamento ROV, evitamento ostacoli ROV, acquisizione dati ROV e ispezione ROV.
Single-molecule force spectroscopy system
Patent published on the 2026-10-15 in WO under Ref WO2026213682 by THE UNIV OF BRITISH COLUMBIA [CA] (Li Isaac [ca], Yasunaga Adam [ca])
Abstract: Single-molecule force spectroscopy systems are described. The systems include a microfluidic device with microchannels; inlets; outlets; and chambers, with the chambers having a functionalized surface with one or more targets; a force-generating component tethered to the target; a liquid reagent for flowing through the microfluidic device; and an optical, electrical or electrochemical device or system for measuring a property of the target or the force-generating component within the chambers. T[...]
Our summary: Single-molecule force spectroscopy systems utilize microfluidic devices with functionalized chambers. These systems measure forces on targets using a force-generating component and liquid reagents. The components are designed to exhibit hydrodynamic drag under fluidic conditions.
microfluidics, single-molecule, force spectroscopy, hydrodynamic drag
Patent
Hydrodynamic cavitation generator
Patent published on the 2026-10-14 in SK under Ref SK2872026U by BAJCIK SLAVOMIR [SK] (BajČÍk SlavomÍr [sk])
Abstract: The technical solution presents a structural arrangement of a hydrodynamic cavitation generator for generating controlled cavitation. The device consists of a static hermetic housing with an inlet and an outlet, in which a cylindrical drum rotor is rotatably mounted on a central shaft. This one rotor is provided with a grid of blind cylindrical holes on its circumference. A working gap in the range of 0.5 mm to 2 mm is defined between the rotor and the inner wall of the housing. By rotating one [...]
Our summary: The hydrodynamic cavitation generator features a static hermetic housing with a rotatable cylindrical drum rotor. It generates controlled cavitation by creating a working gap between the rotor and housing. The adiabatic collapse of microbubbles results in continuous hydro-acoustic heating and homogenization of the medium.
cavitation, hydrodynamics, rotor, hydro-acoustic heating
Patent
Dynamic DWI detects respiratory modulation of brain parenchymal hydrodynamics
Published on 2026-09-24 by @MIT
Abstract: AbstractThe circulation of cerebrospinal fluid (CSF) within the brain parenchyma and its exchange with interstitial fluid (ISF) are essential for maintaining homeostasis and clearing interstitial waste. However, the physiological forces driving parenchymal hydrodynamics remain unclear. Cardiac pulsation alone may be insufficient to drive parenchymal flow, while respiration has emerged as an additional contributor. To date, however, most respiration-related studies have focused on the ventricular[...]
Our summary: This study investigates the influence of respiration on brain parenchymal hydrodynamics using dynamic diffusion-weighted imaging. It finds that parenchymal fluid motion is coupled with respiration, exhibiting a latency of 0.7 seconds. The research suggests that both respiration and cardiac pulsation play complementary roles in regulating brain fluid dynamics.
Dynamic DWI, parenchymal hydrodynamics, respiratory modulation, cerebrospinal fluid
Publication
Multistage stimuli-responsive nanoparticle platform for intracellular delivery of biologics and drug conjugates thereof
Patent published on the 2026-09-24 in WO under Ref WO2026198863 by LIU QIYONG PETER [US] (Liu Qiyong [us])
Abstract: A multistage, stimuli-responsive nanoparticle platform (TRIDENT) for targeted intracellular delivery of biologic therapeutics is disclosed. The platform comprises an amine-functionalized crosslinked dextran shell on an iron oxide core, with a tunable hydrodynamic diameter of 15-60 nm designed to exceed the renal filtration threshold while enabling tumor accumulation via the EPR effect. Therapeutic payloads — including nanobodies, antibody fragments, peptides, enzymes, and protein-drug conjugat[...]
Our summary: The TRIDENT platform is a multistage, stimuli-responsive nanoparticle system designed for targeted intracellular delivery of biologics. It features a crosslinked dextran shell on an iron oxide core, allowing for tumor accumulation while overcoming renal filtration. The platform enables cytosolic release of therapeutic payloads and supports treatment of heterogeneous tumors.
nanoparticles, intracellular delivery, stimuli-responsive, drug conjugates
Patent
Suspension fork sealhead for increased component lubrication
Patent published on the 2026-09-23 in GB under Ref GB2704821 by FOX FACTORY INC [US] (William M Becker [us], Damon Gilbert [us])
Abstract: A suspension fork comprising a fork leg comprising an upper tube 103 and a lower tube 106 slidably engaged with one another for compression and rebound, a damper assembly 172 positioned within the fork leg, the damper assembly 172 comprising a shaft 164 and a sealhead 168 coupled to the shaft 164, and a reservoir 176 configured to retain bath oil 174 in proximity to the sealhead 168. The sealhead 168 is sized and positioned to splash bath oil 174 upwards D1 when the sealhead 168 is driven into t[...]
Our summary: The suspension fork features a sealhead designed for enhanced lubrication. The sealhead splashes bath oil upwards during compression to lubricate internal components. Its hydrodynamic profile ensures controlled oil displacement for optimal performance.
suspension fork, sealhead, lubrication, hydrodynamic profile
Patent
Method and system for determining the viability of biological particles
Patent published on the 2026-09-23 in EP under Ref EP4810940 by UNIV DEGLI STUDI DI CATANIA [IT] (Bucolo Maide Angela Rita [it], Guarino Francesca [it], Cutuli Emanuela [it])
Abstract: Method for determining a degree of vitality of first biological particles comprising a procedure of subjecting (Step 2) a first dilution of said first biological particles to a periodic hydrodynamic stimulus and of comparing a relative temporal trend of a first signal representative of a velocity of the biological particles in response to the hydrodynamic stimulus with a second reference trend representative of a reference velocity signal and of calculating (Step 4) a vitality value of the biolo[...]
Our summary: The method assesses the vitality of biological particles by applying a hydrodynamic stimulus. It compares the velocity response of the particles to a reference trend. A vitality value is calculated based on the deviation from the reference signal.
biological particles, vitality assessment, hydrodynamic stimulus, signal comparison
Patent
Microstirring devices, systems, and methods for sublingual drug delivery
Patent published on the 2026-09-10 in WO under Ref WO2026188001 by THE REGENTS OF THE UNIV OF CALIFORNIA [US] (Wang Joseph [us], Qualliotine Jesse [us], Chen Chuanrui [us], Askarinam Nelly [us])
Abstract: Disclosed are devices, systems and methods for microstructure-based microstirring for sublingual drug delivery. In some embodiments, a microrobotic sublingual pill device is disclosed that can rapidly and efficiently deliver a substance (a drug) through a sublingual route caused by a microstirring technique controlled by the microstirrer structures embedded in the pill device, which can actively enhance the transport of the one or more substances through localized hydrodynamic flow upon contact [...]
Our summary: The content discusses devices and methods for microstirring to enhance sublingual drug delivery. A microrobotic pill device is designed to improve substance transport through localized hydrodynamic flow. The microstirring technique is activated upon contact with saliva, facilitating efficient drug absorption.
microstirring, sublingual delivery, drug delivery systems, microrobotics
Patent
Spherical MgSiO3–NH2 Adsorbents with Optimized Surface Chemistry for Humidity-Enhanced Direct Air CO2 Capture
Published on 2026-02-03 by Sungho Park, Hyeok-Jung Kim @MDPI
Abstract: Amine-functionalized solid adsorbents are widely recognized as promising candidates for direct air capture of CO2; however, their practical deployment remains constrained by humidity-dependent adsorption behavior and poor packed-bed operability arising from irregular particle morphology and fines generation. Rather than focusing solely on maximizing intrinsic adsorption capacity, this study addresses these process-level limitations through an integrated design strategy combining particle morphol[...]
Our summary: This study presents optimized spherical magnesium silicate adsorbents for CO2 capture. It addresses limitations in humidity-dependent adsorption and particle morphology. The adsorbents show enhanced performance under humid conditions, achieving significant carbon dioxide capture capacities.
Adsorbents, CO2 capture, Surface chemistry, Humidity-enhanced
Publication